Year: 2026
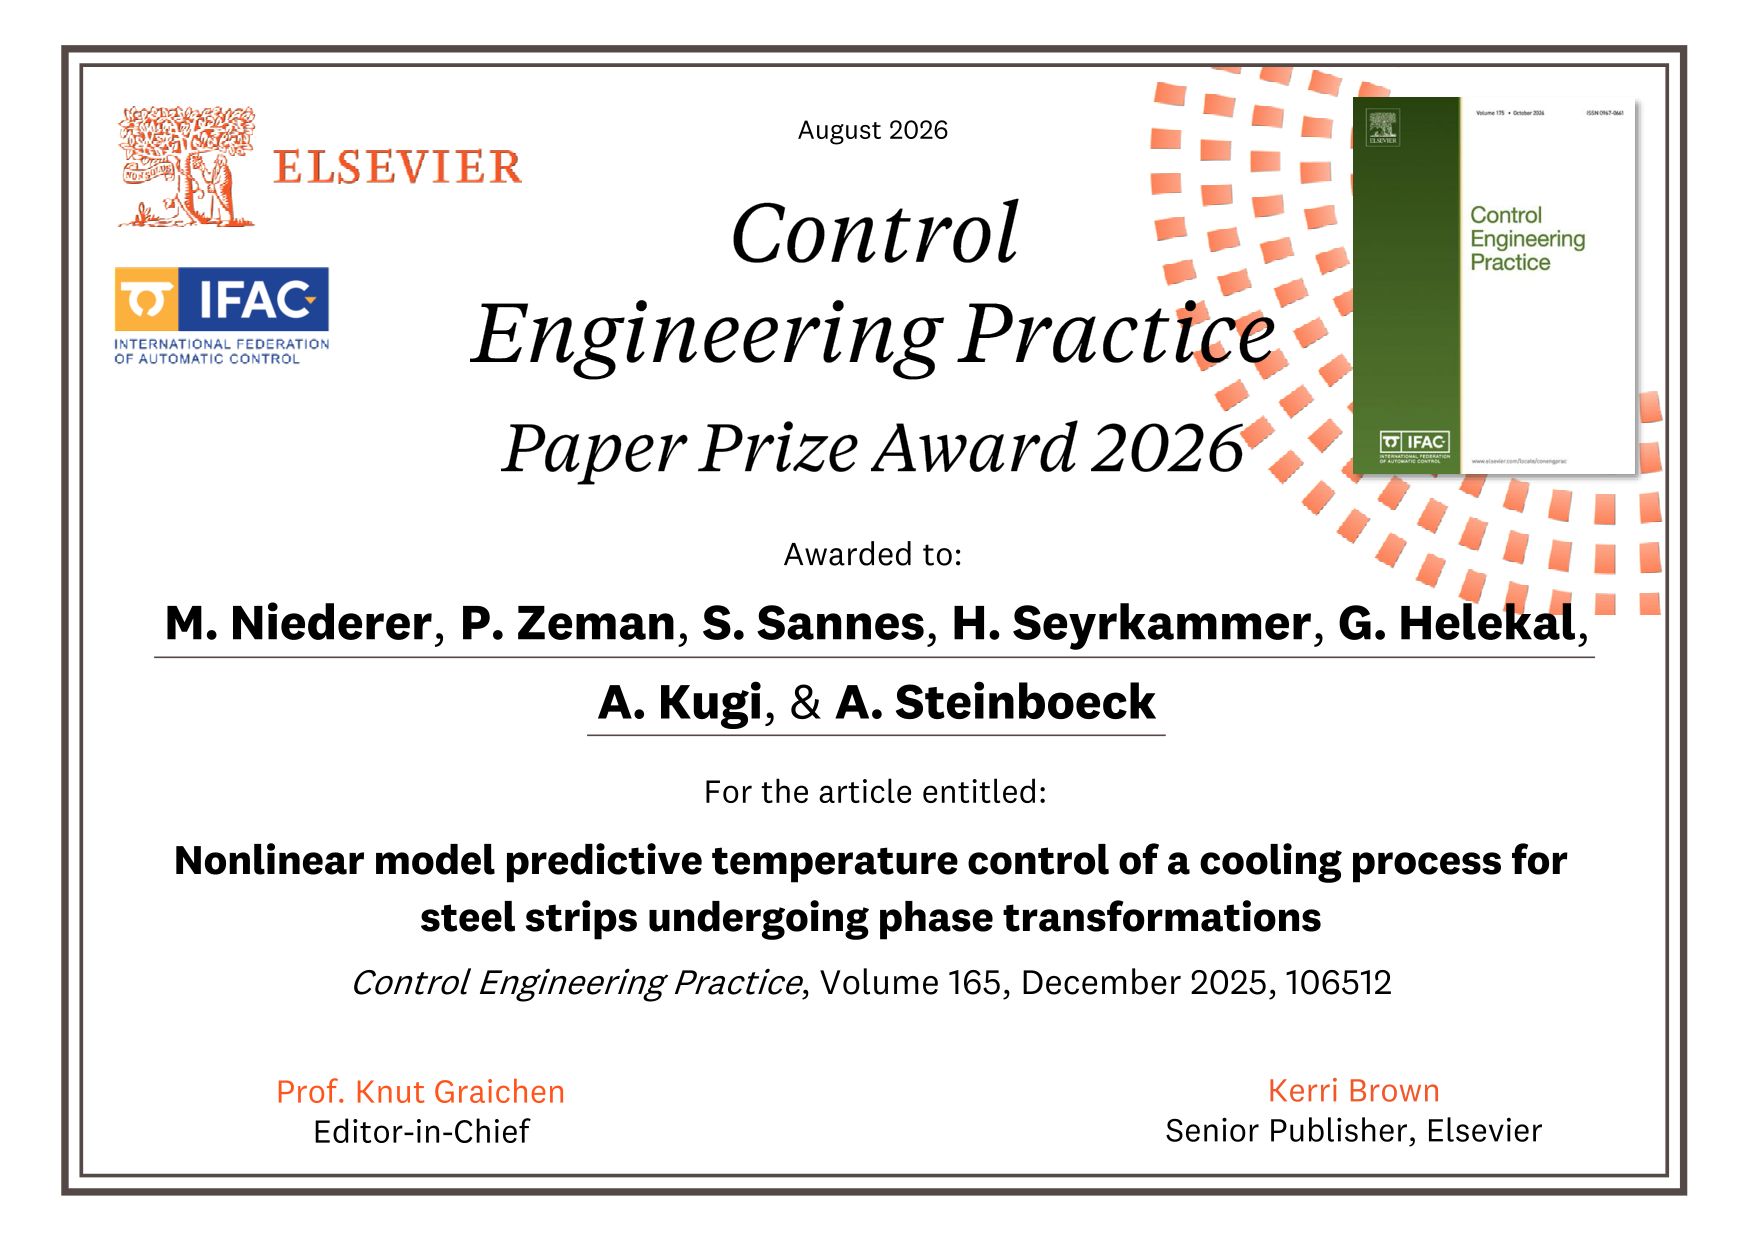
07.09.2026 Control Engineering Practice Paper Prize 2026
The power of collaboration between research and industry.
We are delighted that our joint research by AIT Austrian Institute of Technology, TU Wien ACIN and voestalpine Stahl GmbH has received the Control Engineering Practice Paper Prize 2026.
The prize is a triennial IFAC award recognizing outstanding papers published in Control Engineering Practice during the three years preceding each IFAC World Congress.
The awarded paper, “Nonlinear model predictive temperature control of a cooling process for steel strips undergoing phase transformations”, presents a nonlinear model predictive control approach that was successfully implemented at the voestalpine production plant and is now in continuous operation.
A great example of how scientific excellence, close collaboration and advanced control engineering can translate into measurable industrial impact.
Congratulations to the entire team!
16.07.2026 Auszeichnung der Fahrzeugverband-Jubiläumsstiftung an Dr. René Lenz
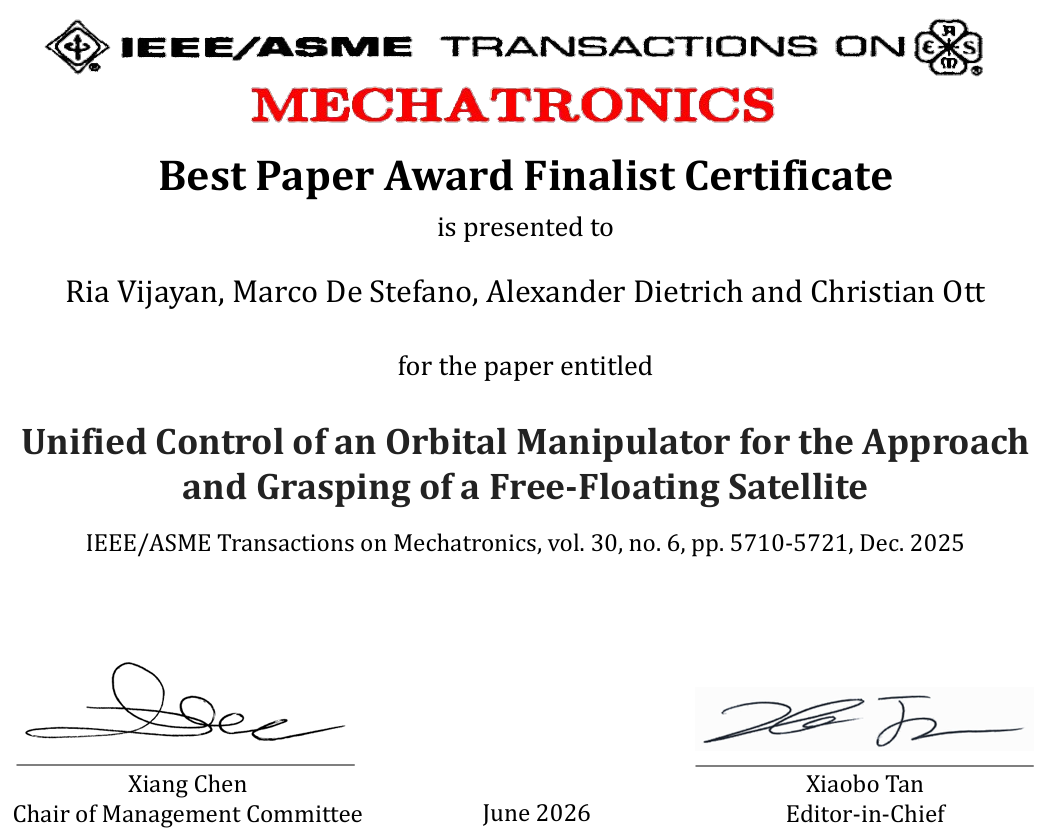
22.05.2026 2026 TMECH Best Paper Award Finalist
We are happy to announce that the paper “Unified Control of an Orbital Manipulator for the Approach and Grasping of a Free-Floating Satellite,” published in IEEE/ASME Transactions on Mechatronics (vol. 30, no. 6, December 2025), was named a finalist for the 2026 TMECH Best Paper Award. The paper was selected as one of 5 finalists from over 700 papers published in TMECH in 2025.
19.05.2026 Studienpreis der SEW-EURODRIVE-Stiftung
15.05.2026 1st Place at Mobile Manipulation Challenge
The paper “Per-Group Error, Not Total MSE: Fine-Tuning Vision-Language-Action Models for 11-DoF Mobile Manipulation” (Pau Montagut Bofi, Mario García Blasco, Tessa Pulli, Markus Vincze) participated in the Mobile Manipulation Challenge organized by Toyota at the workshop “From Data to Decisions: VLA Pipelines for Real Robot”. This workshop is part of the IEEE International Conference on Robotics and Automation (ICRA) 2026.
Today it has been announced that this paper won the first prize, outperforming 36 participants from around the world.
Congratulations to the team on this excellent achievement!